turn 1
01: Inspected goal and initial robot state to plan trash collection. Goal received; both hands empty.
move_base({"x": 0.0, "y": 0.0, "yaw": 1.57}) → "arrived, err=0.00 m"move_base({"x": 0.0, "y": 0.0, "yaw": 1.57}) → "arrived, err=0.00 m"
get_proprio({}) → {"odometry": {"pos_since_start": [0.0, 0.0, 0.0], "quat_since_start": [-0.0, 0.0, 0.0, 1.0]}, "holding": {"lefmove_base({"x": 0.0, "y": 0.15, "yaw": 1.57}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-0.0, 0.013, 0.005], "quat_since_start": [0.00779, -0.0028, 0.01674, 0.99983move_base({"x": 0.0, "y": 0.65, "yaw": 1.57}) → "arrived, err=0.15 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-0.0009, 0.5018, -0.0005], "quat_since_start": [-0.00819, -0.01471, 0.4807, move_base({"x": -0.5, "y": 0.5, "yaw": 3.14}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-0.3563, 0.5014, -0.0098], "quat_since_start": [-0.00736, -0.00575, 0.7836, move_base({"x": -0.7, "y": 0.0, "yaw": 3.14}) → "arrived, err=0.15 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-0.6168, 0.1219, -0.0146], "quat_since_start": [-0.00928, -0.00144, 0.98799,get_proprio({}) → {"odometry": {"pos_since_start": [-0.6168, 0.1219, -0.0146], "quat_since_start": [-0.00928, -0.00144, 0.98799,depth_to_cam({"u": 280, "v": 293, "cam": "head"}) → {"xyz_cam": [0.40991, -0.54313, -2.09053], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 285, "v": 215, "cam": "head"}) → {"xyz_cam": [1.09317, 0.60732, -4.95571], "note": "相机系: x 右, y 上, -z 前向"}
set_torso({"t": 1.0}) → "torso set to 1.00 (0=upright,1=lowest)"
get_proprio({}) → {"odometry": {"pos_since_start": [-1.6643, 0.8585, -0.0341], "quat_since_start": [-0.00898, -0.00274, 0.95528,get_proprio({}) → {"odometry": {"pos_since_start": [-1.6643, 0.8585, -0.0341], "quat_since_start": [-0.00898, -0.00274, 0.95528,depth_to_cam({"u": 234, "v": 328, "cam": "head"}) → {"xyz_cam": [-0.02308, -0.33855, -0.78482], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 234, "v": 333, "cam": "head"}) → {"xyz_cam": [-0.02286, -0.35429, -0.77716], "note": "相机系: x 右, y 上, -z 前向"}
move_base({"x": -1.98, "y": 1.08, "yaw": 2.54}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-1.8674, 1.002, -0.0379], "quat_since_start": [-0.00897, -0.00276, 0.95465, get_proprio({}) → {"odometry": {"pos_since_start": [-1.8674, 1.002, -0.0379], "quat_since_start": [-0.00897, -0.00276, 0.95465, depth_to_cam({"u": 231, "v": 402, "cam": "head"}) → {"xyz_cam": [-0.03032, -0.54579, -0.68729], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 232, "v": 391, "cam": "head"}) → {"xyz_cam": [-0.02757, -0.52038, -0.70303], "note": "相机系: x 右, y 上, -z 前向"}
move_eef({"arm": "left", "pos": [0.53, 0.03, 0.14], "quat": [0.0, 0.94, 0.0, -0.342]}) → "规划不出可行轨迹。目标在底盘水平方向 0.53 m、高度 0.14 m 处,超出当前姿态的运动学可达范围;通常需要先移动底盘或调整躯干再试。"
move_eef({"arm": "left", "pos": [0.45, 0.22, 0.22], "quat": [0.0, 0.7071, 0.0, 0.7071]}) → "规划不出可行轨迹。目标在底盘水平方向 0.50 m、高度 0.22 m 处,超出当前姿态的运动学可达范围;通常需要先移动底盘或调整躯干再试。"
move_eef({"arm": "left", "pos": [0.13, 0.25, 0.33], "quat": [0.0, 0.939, 0.0, -0.344]}) → "规划不出可行轨迹。目标在底盘水平方向 0.28 m、高度 0.33 m 处,超出当前姿态的运动学可达范围;通常需要先移动底盘或调整躯干再试。"
set_torso({"t": 0.6}) → "torso set to 0.60 (0=upright,1=lowest)"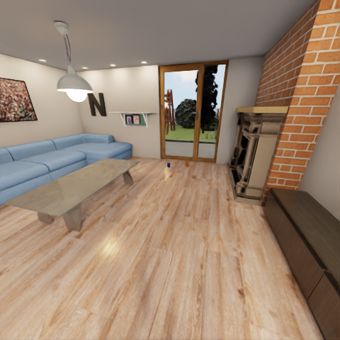
move_eef({"arm": "left", "pos": [0.53, 0.03, 0.16], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.000 m"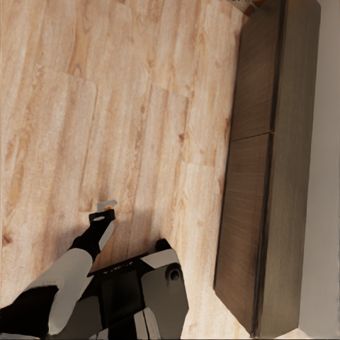
get_proprio({}) → {"odometry": {"pos_since_start": [-1.8679, 1.0023, -0.0379], "quat_since_start": [-0.00897, -0.00276, 0.95458,move_eef({"arm": "left", "pos": [0.535, 0.03, 0.11], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.001 m"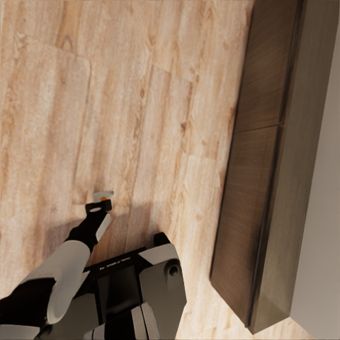
gripper({"arm": "left", "mode": "close"}) → "grasping=True"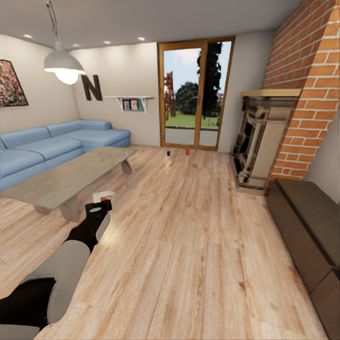
get_proprio({}) → {"odometry": {"pos_since_start": [-1.8681, 1.0023, -0.0292], "quat_since_start": [-0.03347, 0.00488, 0.95402, move_eef({"arm": "left", "pos": [0.35, 0.28, 0.7], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.000 m"
move_base({"x": -1.8, "y": 0.4, "yaw": 4.1}) → "arrived, err=0.15 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-1.8171, 0.5473, -0.0072], "quat_since_start": [-0.04977, 0.06126, -0.97379,move_base({"x": -1.35, "y": 0.0, "yaw": 5.0}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-1.4426, 0.1075, -0.0298], "quat_since_start": [0.00659, -0.00734, -0.6809, move_base({"x": -0.7, "y": 0.2, "yaw": 6.28}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-0.8361, 0.1829, -0.0187], "quat_since_start": [0.00162, -0.0091, -0.17231, get_proprio({}) → {"odometry": {"pos_since_start": [-0.8361, 0.1829, -0.0187], "quat_since_start": [0.00162, -0.0091, -0.17231, depth_to_cam({"u": 191, "v": 325, "cam": "head"}) → {"xyz_cam": [-0.36716, -0.63692, -1.5286], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 179, "v": 324, "cam": "head"}) → {"xyz_cam": [-0.43407, -0.59774, -1.45165], "note": "相机系: x 右, y 上, -z 前向"}
get_proprio({}) → {"odometry": {"pos_since_start": [0.0206, -0.1236, -0.0028], "quat_since_start": [0.00161, -0.0091, -0.17119, get_proprio({}) → {"odometry": {"pos_since_start": [0.0206, -0.1236, -0.0028], "quat_since_start": [0.00161, -0.0091, -0.17119, depth_to_cam({"u": 240, "v": 100, "cam": "left_wrist"}) → {"xyz_cam": [0.0, 0.17673, -0.49064], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 90, "v": 110, "cam": "left_wrist"}) → {"xyz_cam": [-0.09691, 0.08399, -0.2511], "note": "相机系: x 右, y 上, -z 前向"}
get_proprio({}) → {"odometry": {"pos_since_start": [0.0253, -0.125, -0.0027], "quat_since_start": [0.00161, -0.0091, -0.1713, 0.move_base({"x": -1.8, "y": 1.0, "yaw": 2.54}) → "arrived, err=0.15 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-1.6759, 0.9236, -0.0343], "quat_since_start": [-0.00889, -0.00307, 0.9507, get_proprio({}) → {"odometry": {"pos_since_start": [-1.6759, 0.9236, -0.0343], "quat_since_start": [-0.00889, -0.00307, 0.9507, depth_to_cam({"u": 230, "v": 229, "cam": "head"}) → {"xyz_cam": [-0.18761, 0.20637, -3.82732], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 254, "v": 229, "cam": "head"}) → {"xyz_cam": [0.2673, 0.21002, -3.89492], "note": "相机系: x 右, y 上, -z 前向"}
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3643, 2.9344, -0.0844], "quat_since_start": [-0.00892, -0.00293, 0.94875,get_proprio({}) → {"odometry": {"pos_since_start": [-4.3643, 2.9344, -0.0844], "quat_since_start": [-0.00892, -0.00293, 0.94875,depth_to_cam({"u": 337, "v": 15, "cam": "left_wrist"}) → {"xyz_cam": [0.08735, 0.20261, -0.34999], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 300, "v": 478, "cam": "head"}) → {"xyz_cam": [0.24432, -0.96912, -0.83068], "note": "相机系: x 右, y 上, -z 前向"}
gripper({"arm": "left", "mode": "close"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3637, 2.9335, -0.0723], "quat_since_start": [0.00756, -0.01193, 0.94874, gripper({"arm": "left", "mode": "open"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3618, 2.9319, -0.0746], "quat_since_start": [0.0042, -0.01077, 0.94878, 0depth_to_cam({"u": 169, "v": 361, "cam": "head"}) → {"xyz_cam": [-0.272, -0.46355, -0.78153], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 300, "v": 335, "cam": "head"}) → {"xyz_cam": [0.21351, -0.33806, -0.72593], "note": "相机系: x 右, y 上, -z 前向"}set_torso({"t": 0.6}) → "torso set to 0.60 (0=upright,1=lowest)"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3593, 2.9299, -0.0833], "quat_since_start": [-0.00827, -0.00623, 0.94882,depth_to_cam({"u": 351, "v": 389, "cam": "left_wrist"}) → {"xyz_cam": [0.05285, -0.07095, -0.18506], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 304, "v": 335, "cam": "head"}) → {"xyz_cam": [0.22791, -0.3383, -0.72646], "note": "相机系: x 右, y 上, -z 前向"}move_eef({"arm": "left", "pos": [0.49, 0.29, 0.065], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.004 m"
gripper({"arm": "left", "mode": "close"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3593, 2.9294, -0.0802], "quat_since_start": [-0.00977, -0.01151, 0.94902,move_eef({"arm": "right", "pos": [0.63, -0.24, 0.11], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.037 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3593, 2.9296, -0.0819], "quat_since_start": [-0.00744, -0.01047, 0.94902,get_proprio({}) → {"odometry": {"pos_since_start": [-4.3593, 2.9296, -0.0819], "quat_since_start": [-0.00744, -0.01047, 0.94902,depth_to_cam({"u": 201, "v": 371, "cam": "right_wrist"}) → {"xyz_cam": [-0.00998, -0.03351, -0.09943], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 230, "v": 328, "cam": "head"}) → {"xyz_cam": [-0.04464, -0.3928, -0.91058], "note": "相机系: x 右, y 上, -z 前向"}
gripper({"arm": "right", "mode": "close"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3593, 2.9294, -0.0765], "quat_since_start": [-0.03065, 0.0043, 0.94851, 0move_eef({"arm": "left", "pos": [0.445, 0.29, 0.18], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.022 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3591, 2.9295, -0.0843], "quat_since_start": [-0.00892, -0.00293, 0.94886,get_proprio({}) → {"odometry": {"pos_since_start": [-4.3591, 2.9295, -0.0843], "quat_since_start": [-0.00892, -0.00293, 0.94886,depth_to_cam({"u": 235, "v": 143, "cam": "left_wrist"}) → {"xyz_cam": [-0.00215, 0.04172, -0.16715], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 174, "v": 214, "cam": "left_wrist"}) → {"xyz_cam": [-0.03051, 0.01202, -0.17968], "note": "相机系: x 右, y 上, -z 前向"}
gripper({"arm": "left", "mode": "close"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3576, 2.9281, -0.063], "quat_since_start": [0.02643, 0.00122, 0.9487, 0.3get_proprio({}) → {"odometry": {"pos_since_start": [-4.3576, 2.9281, -0.063], "quat_since_start": [0.02643, 0.00122, 0.9487, 0.3depth_to_cam({"u": 296, "v": 350, "cam": "head"}) → {"xyz_cam": [0.21286, -0.41811, -0.7754], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 296, "v": 338, "cam": "head"}) → {"xyz_cam": [0.21273, -0.37228, -0.77496], "note": "相机系: x 右, y 上, -z 前向"}
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3559, 2.9268, -0.075], "quat_since_start": [0.00659, -0.00099, 0.94894, 0get_proprio({}) → {"odometry": {"pos_since_start": [-4.3559, 2.9268, -0.075], "quat_since_start": [0.00659, -0.00099, 0.94894, 0depth_to_cam({"u": 266, "v": 181, "cam": "right_wrist"}) → {"xyz_cam": [0.01221, 0.02771, -0.18256], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 268, "v": 108, "cam": "right_wrist"}) → {"xyz_cam": [0.01219, 0.05745, -0.16916], "note": "相机系: x 右, y 上, -z 前向"}
gripper({"arm": "right", "mode": "close"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3552, 2.9249, -0.084], "quat_since_start": [-0.00855, -0.00247, 0.94876, move_eef({"arm": "right", "pos": [0.47, -0.22, 0.08], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.007 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3555, 2.9245, -0.0715], "quat_since_start": [0.00374, -0.0261, 0.94859, 0get_proprio({}) → {"odometry": {"pos_since_start": [-4.3555, 2.9245, -0.0715], "quat_since_start": [0.00374, -0.0261, 0.94859, 0depth_to_cam({"u": 257, "v": 235, "cam": "right_wrist"}) → {"xyz_cam": [0.00597, 0.00175, -0.13641], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 239, "v": 275, "cam": "right_wrist"}) → {"xyz_cam": [-0.00037, -0.01287, -0.14287], "note": "相机系: x 右, y 上, -z 前向"}
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3559, 2.9229, -0.0587], "quat_since_start": [0.00581, -0.07862, 0.94584, depth_to_cam({"u": 253, "v": 270, "cam": "right_wrist"}) → {"xyz_cam": [0.00279, -0.00645, -0.08351], "note": "相机系: x 右, y 上, -z 前向"}gripper({"arm": "right", "mode": "close"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3557, 2.9222, -0.047], "quat_since_start": [0.02478, -0.07814, 0.94613, 0move_eef({"arm": "right", "pos": [0.4, -0.23, 0.09], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.000 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3554, 2.9233, -0.0699], "quat_since_start": [-0.00049, -0.04601, 0.94805,get_proprio({}) → {"odometry": {"pos_since_start": [-4.3554, 2.9233, -0.0699], "quat_since_start": [-0.00049, -0.04601, 0.94805,depth_to_cam({"u": 452, "v": 291, "cam": "head"}) → {"xyz_cam": [0.60817, -0.1463, -0.58522], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 461, "v": 282, "cam": "head"}) → {"xyz_cam": [0.61353, -0.1166, -0.56634], "note": "相机系: x 右, y 上, -z 前向"}
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3547, 2.9212, -0.0522], "quat_since_start": [0.02533, -0.05315, 0.94778, depth_to_cam({"u": 240, "v": 240, "cam": "right_wrist"}) → {"xyz_cam": [0.0, -0.0, -0.21984], "note": "相机系: x 右, y 上, -z 前向"}get_proprio({}) → {"odometry": {"pos_since_start": [-4.3547, 2.9212, -0.0522], "quat_since_start": [0.02533, -0.05315, 0.94778, depth_to_cam({"u": 324, "v": 223, "cam": "right_wrist"}) → {"xyz_cam": [0.03094, 0.00626, -0.14314], "note": "相机系: x 右, y 上, -z 前向"}
gripper({"arm": "right", "mode": "close"}) → "grasping=True"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3548, 2.9209, -0.0554], "quat_since_start": [0.0077, -0.0882, 0.9452, 0.3move_eef({"arm": "right", "pos": [0.35, -0.28, 0.65], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.014 m"
move_eef({"arm": "left", "pos": [0.35, 0.28, 0.7], "quat": [0.0, 1.0, 0.0, 0.0]}) → "到位, 误差 0.002 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-4.3543, 2.9216, -0.0832], "quat_since_start": [-0.00673, -0.00084, 0.94884,move_base({"x": -1.8, "y": 1.0, "yaw": -0.65}) → "arrived, err=0.15 m"
get_proprio({}) → {"odometry": {"pos_since_start": [-1.916, 1.0878, -0.0388], "quat_since_start": [0.00301, -0.00874, -0.32052, move_base({"x": 0.15, "y": 0.0, "yaw": -0.65}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [0.0247, 0.0661, -0.0027], "quat_since_start": [0.00226, -0.00896, -0.24071, move_base({"x": 0.025, "y": -0.18, "yaw": -0.486}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [0.0261, -0.0361, 0.0018], "quat_since_start": [-0.00596, -0.01238, -0.34807,get_proprio({}) → {"odometry": {"pos_since_start": [0.0261, -0.0361, 0.0018], "quat_since_start": [-0.00596, -0.01238, -0.34807,depth_to_cam({"u": 67, "v": 229, "cam": "left_wrist"}) → {"xyz_cam": [-0.12097, 0.00769, -0.27177], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 381, "v": 229, "cam": "left_wrist"}) → {"xyz_cam": [0.09763, 0.00762, -0.2691], "note": "相机系: x 右, y 上, -z 前向"}
get_proprio({}) → {"odometry": {"pos_since_start": [0.0262, -0.0418, -0.0026], "quat_since_start": [0.0033, -0.00864, -0.35167, get_proprio({}) → {"odometry": {"pos_since_start": [0.0262, -0.0418, -0.0026], "quat_since_start": [0.0033, -0.00864, -0.35167, depth_to_cam({"u": 150, "v": 280, "cam": "left_wrist"}) → {"xyz_cam": [-0.11128, -0.04946, -0.48055], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 9, "v": 270, "cam": "left_wrist"}) → {"xyz_cam": [-0.17504, -0.02273, -0.2945], "note": "相机系: x 右, y 上, -z 前向"}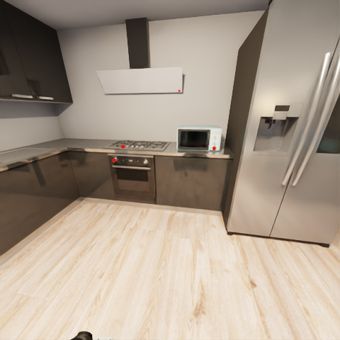
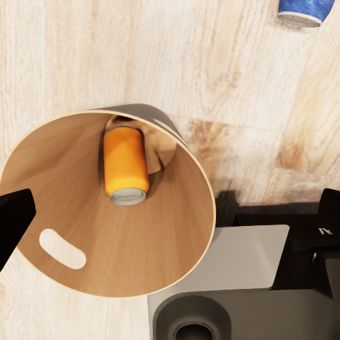
move_base({"x": 0.44, "y": 0.72, "yaw": -0.718}) → "arrived, err=0.14 m"
get_proprio({}) → {"odometry": {"pos_since_start": [0.3737, 0.5982, 0.0038], "quat_since_start": [-0.00299, -0.00876, 0.31762, 0move_eef({"arm": "right", "pos": [-0.25, -0.56, 0.36], "quat": [0.0, 1.0, 0.0, 0.0]}) → "规划不出可行轨迹。目标在底盘水平方向 0.61 m、高度 0.36 m 处,超出当前姿态的运动学可达范围;通常需要先移动底盘或调整躯干再试。"
move_base({"x": -0.05, "y": 0.24, "yaw": -1.5}) → "arrived, err=0.15 m"
get_proprio({}) → {"odometry": {"pos_since_start": [0.0604, 0.3344, -0.001], "quat_since_start": [8e-05, -0.00833, -0.14143, 0.9get_proprio({}) → {"odometry": {"pos_since_start": [0.0604, 0.3344, -0.001], "quat_since_start": [8e-05, -0.00833, -0.14143, 0.9depth_to_cam({"u": 246, "v": 450, "cam": "head"}) → {"xyz_cam": [0.0249, -0.8714, -0.8465], "note": "相机系: x 右, y 上, -z 前向"}depth_to_cam({"u": 292, "v": 450, "cam": "head"}) → {"xyz_cam": [0.20789, -0.83954, -0.81555], "note": "相机系: x 右, y 上, -z 前向"}
done({}) → {"q_score": 0.0, "detail": {"satisfied": 0, "unsatisfied": 1, "success": false}, "turns": 59, "gt_empty_ratio"